 PHYSICAL AI
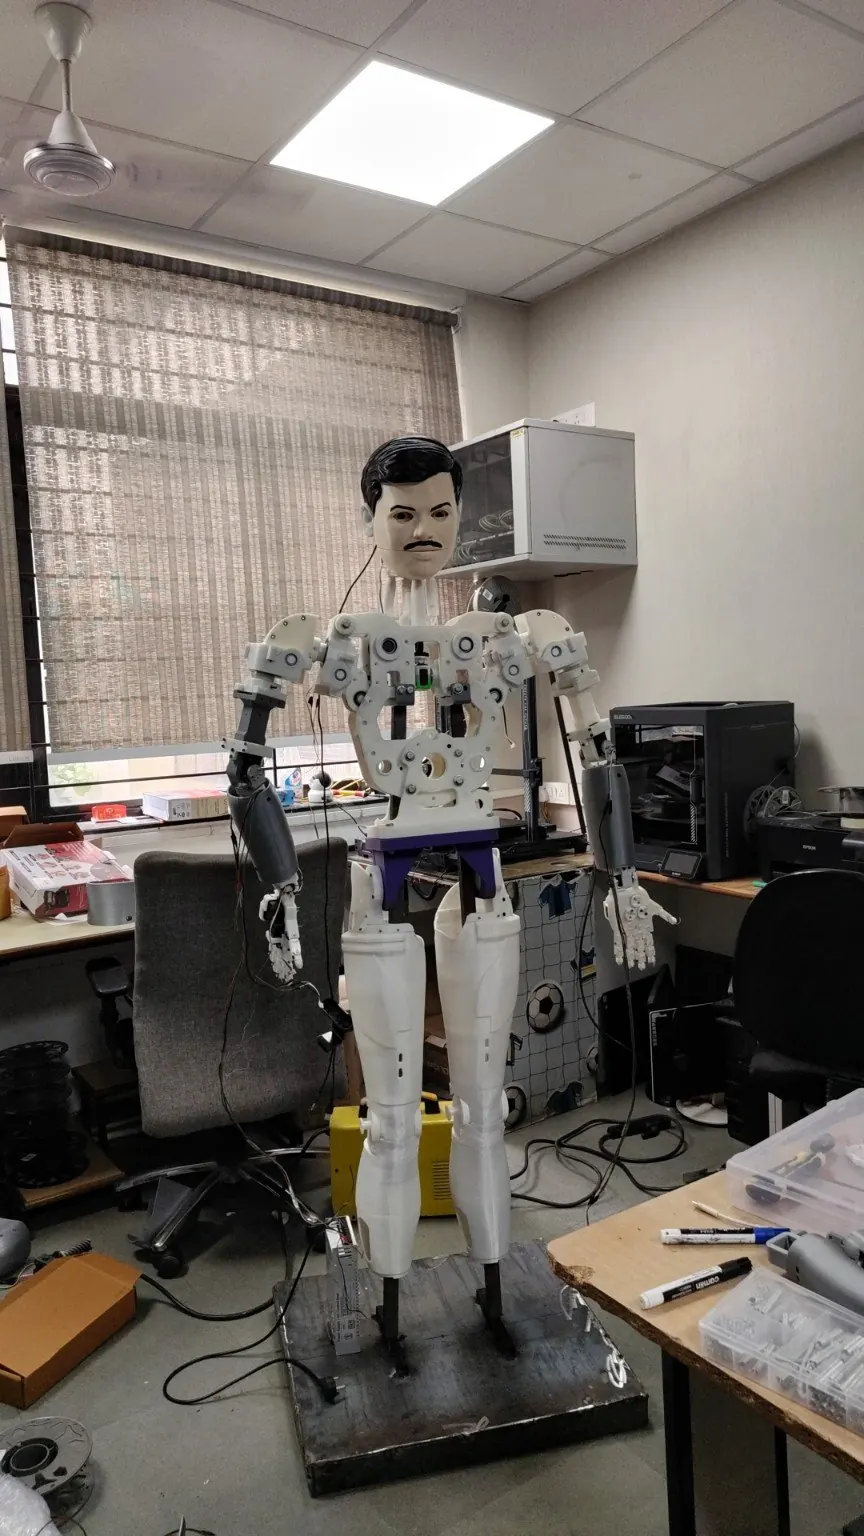
MANAS
Human–robot interaction, articulated motion and embodied AI research. A physical prototype in active integration.
Voice interaction demonstratedMotion & vision in integration
Explore MANAS →Products
Explore the hardware, understand its current capabilities and define the configuration your application needs.
Human–robot interaction, articulated motion and embodied AI research. A physical prototype in active integration.
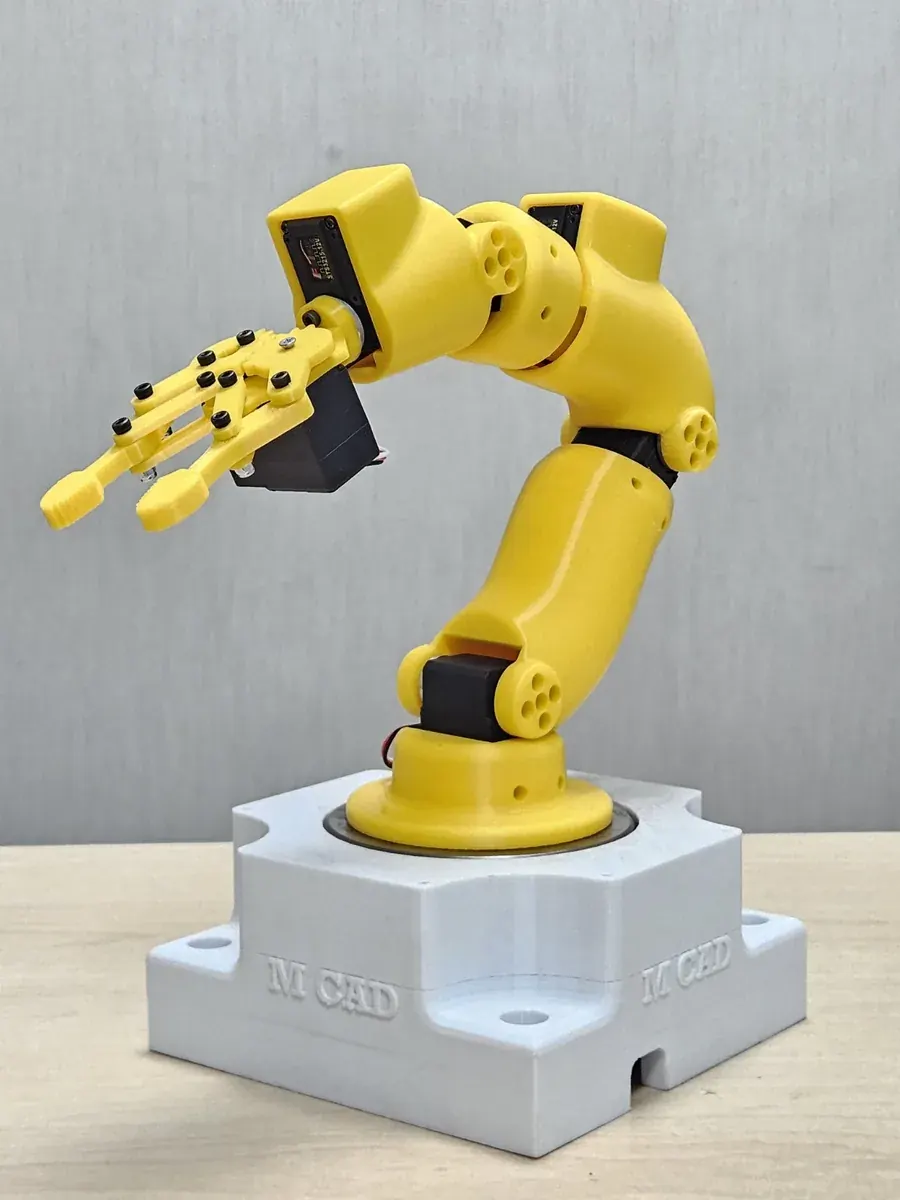
A 6-DOF robotic arm for teaching motion, ROS 2 experimentation and developing perception-to-manipulation workflows.
Project configuration
Institutional colour, approved identity, asset plates and project labelling can be scoped for the system.
Discuss end-effectors, cameras, sensors and control accessories around the intended experiment or pilot.
Define ROS 2 interfaces, digital-workflow requirements and hardware acceptance criteria with our engineering team.
Let’s build what comes next