Lead-Through Teach & Playback
Manually guide Dexter through waypoints, record joint states in real time, and replay smooth autonomous trajectories through a ROS 2-connected control interface.
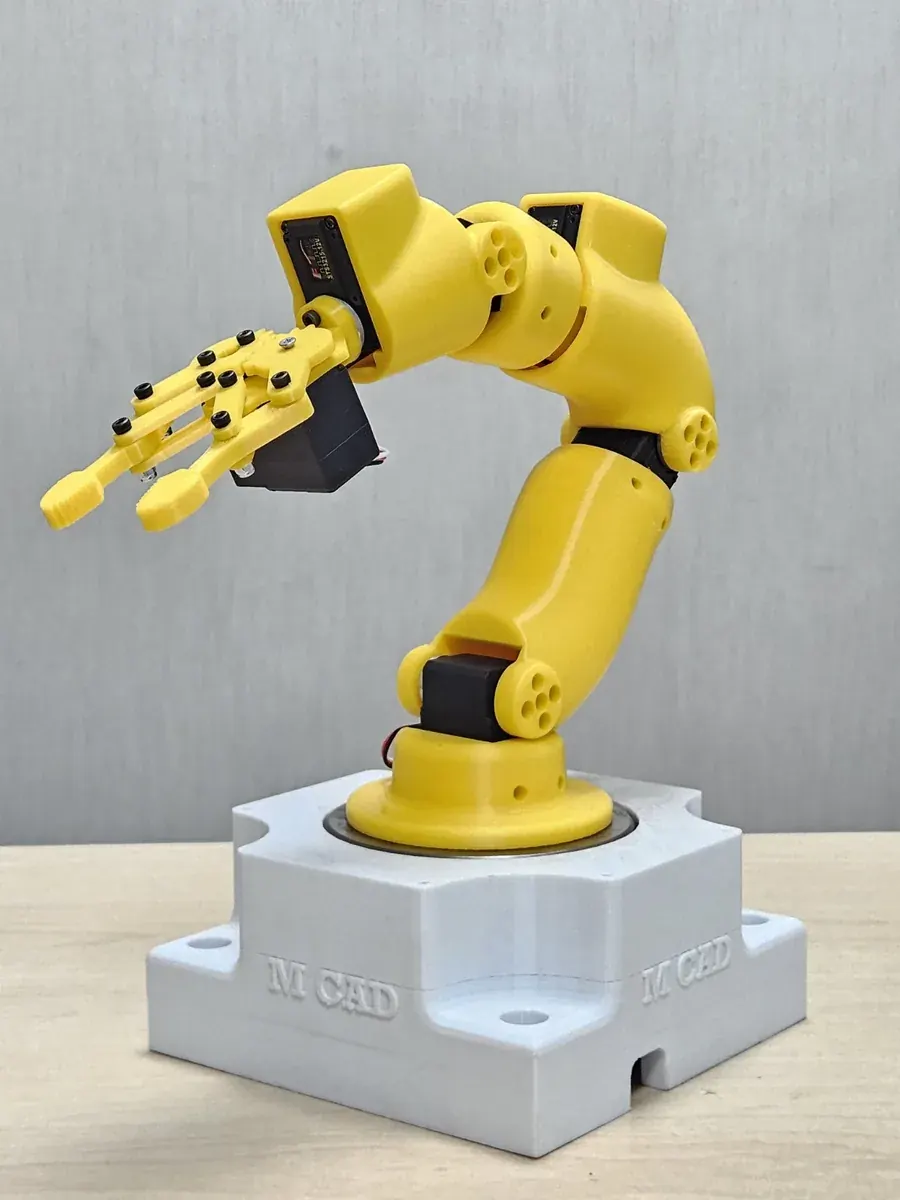
Platform 02 · 6-DOF Robotic Manipulator
A compact, laboratory-ready 6-degree-of-freedom physical manipulator engineered for lead-through teaching, ROS 2 motion control, camera-to-robot calibration, pick-and-place pipelines, and synchronized Unity digital-twin experimentation.
Development status: Teach and playback have been demonstrated. Vision-guided manipulation and digital-twin integration remain in development. Contact us for the current demonstration and project-specific scope.
Core Capabilities
Manually guide Dexter through waypoints, record joint states in real time, and replay smooth autonomous trajectories through a ROS 2-connected control interface.
Inspect joint angles, workspace reach, collision envelopes, and end-effector paths inside a matched 3D Unity scene before executing motion on the physical robot.
Calibrate camera frames to robot base coordinates and evaluate grippers, sensors, and pick-and-place pipelines for academic labs and industrial pilot studies.