CAD to URDF / Xacro
Clean mechanical assemblies exported with accurate link origins, joint axes, limits, and collision meshes for ROS 2 and Gazebo/Unity.
Physical Robot ↔ Digital Clone
Every M CAD Solutions robotic platform pairs physical hardware with a project-specific Unity digital clone—connecting CAD geometry, URDF joint limits, ROS 2 communication, and real-hardware validation in a single loop.
Book a Digital Twin Demonstration →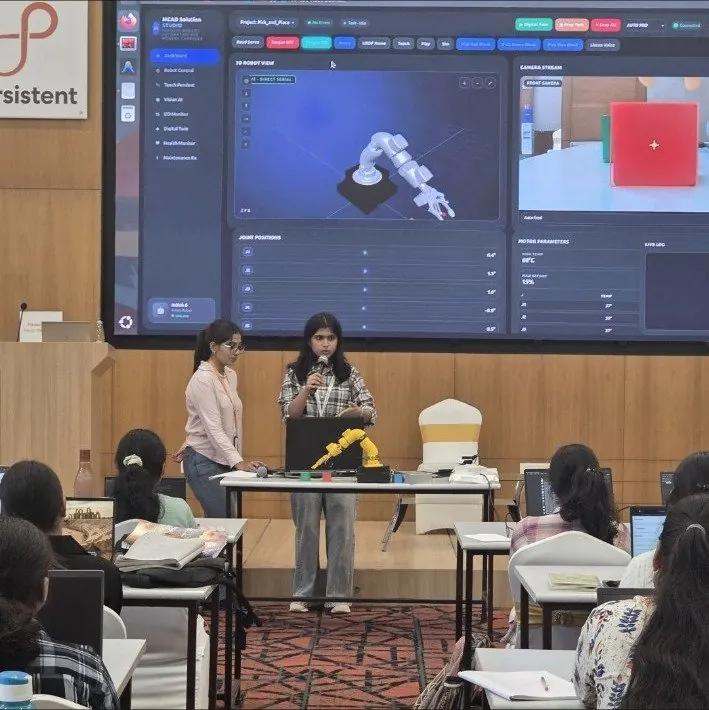
Engineering Workflow
Clean mechanical assemblies exported with accurate link origins, joint axes, limits, and collision meshes for ROS 2 and Gazebo/Unity.
Interactive 3D cell scene for joint-state visualization, reach and trajectory checks, clearance inspection, and simulated sensor views.
Publish and subscribe to joint states and trajectory commands between the digital clone and physical Dexter or MANAS hardware.